
Buildo Development Kit
- Camera resolution
- 4KPER EYE
- Frame rate
- 60FPS
- Latency
- <5MS
- Finger joints tracked
- 21PER HAND
- Force feedback
- Fingertip
- Connectivity
- USB-C+ Wireless
- SDK
- OpenSOURCE
- Compatibility
- BuildoROBOT
Two tools that close
the data loop
Collecting high-quality robot training data requires capturing what the operator sees and what their hands do — simultaneously, at low latency, and in a format your model can consume directly. The Buildo Development Kit is built around those two requirements.
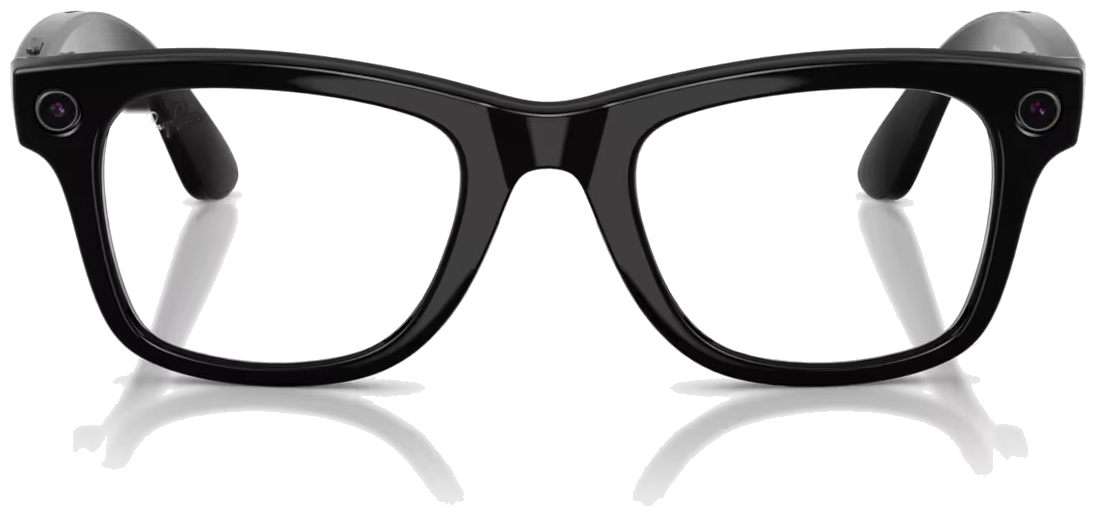
Wide-angle stereo cameras mounted at eye level capture exactly what the operator sees. Every session streams first-person video and depth data directly into the training pipeline — no extra capture rig required.
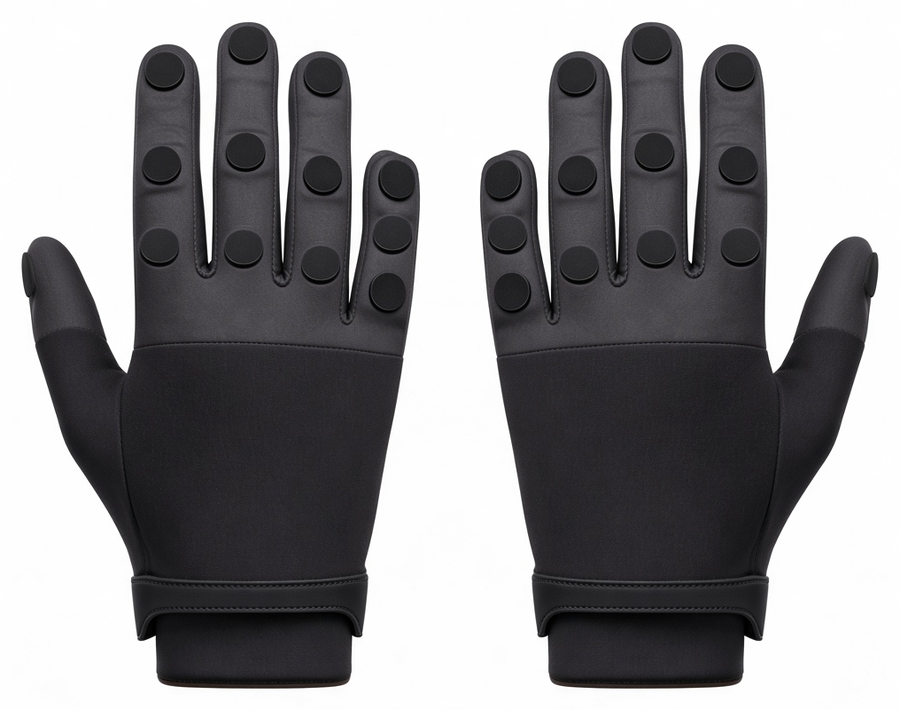
Instrumented gloves mirror your hand pose onto Buildo's five-fingered hands in real time. Force feedback closes the loop so you feel what the robot touches, and every motion is recorded as demonstration data.
See what the
robot sees
The glasses mount at eye level so the camera perspective matches the robot's head position exactly. Stereo depth is computed on-device and streamed alongside the RGB feed — everything your vision model needs, captured in one pass.
Every session is timestamped and synchronised with the glove stream, so vision and action data are always aligned for training.
- Stereo depth - on-device disparity map at 60 fps
- Timestamped frames - aligned with glove joint stream
- USB-C + wireless - tethered or untethered operation
- SDK included - direct integration with Buildo data SDK
Your hands,
the robot's hands
The gloves track all 21 joints per hand and stream pose data to Buildo at under 5 ms latency. Fingertip force feedback returns what the robot is touching so the operator can feel — and react to — the manipulation in real time.
Every teleoperation session is a demonstration. The motion capture runs in parallel with the glasses so you collect a complete observation-action pair with no post-processing.
Decades of dexterous experience live in your hands. The gloves make that experience machine readable in a single session — no reward engineering, no simulation, no domain gap. Plug the output directly into an imitation learning or diffusion policy trainer.
What developers
are building
The kit is the entry point for every data-driven workflow on Buildo. Teams use it to bootstrap new skills, fine-tune existing models, and run large-scale teleoperation studies.
Start collecting
training data
Order the kit, plug it into your Buildo, and run your first demonstration session the same day. Every recording feeds directly into the robot app store training pipeline.